
Differentiable Solver for Time-dependent Deformation Problems with Contact
ACM Transactions on Graphics (SIGGRAPH), 2024

Senior Physics Engine Development Engineer · Tesla Optimus
I build physics simulation systems for robotics and computer graphics. My work centers on robust contact and deformation solvers, and on the optimization problems that sit on top of them — shape design, material estimation, and control through differentiable simulation.
I hold a Ph.D. in Computer Science from the Courant Institute of Mathematical Sciences, New York University, where I was a member of the Geometric Computing Lab, advised by Daniele Panozzo and Denis Zorin. Before that I received a B.S. in Applied Mathematics from the University of Science and Technology of China.


ACM Transactions on Graphics (SIGGRAPH), 2024

RSS Workshop on Robot Hardware-Aware Intelligence, 2025
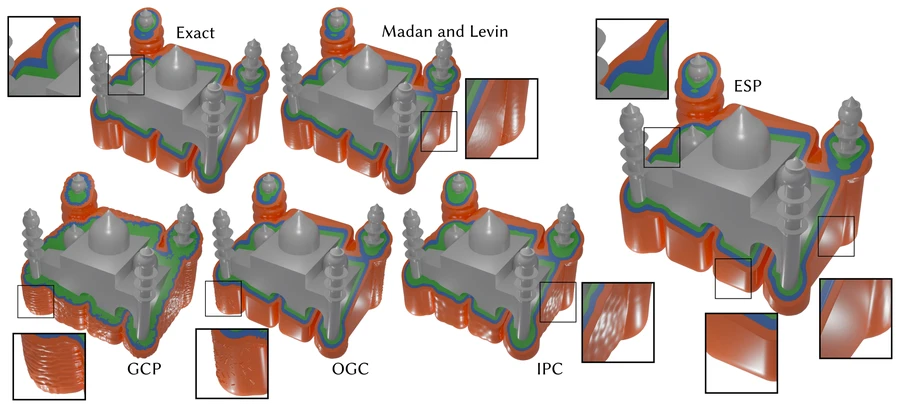

SIGGRAPH Conference Papers, 2025

ACM Transactions on Graphics (SIGGRAPH), 2025

ACM Transactions on Graphics (SIGGRAPH), 2025

ACM Transactions on Graphics (SIGGRAPH), 2025

ACM Transactions on Graphics (SIGGRAPH Asia), 2024

Computer Graphics Forum (SGP), 2024

arXiv preprint, 2021

A polyvalent C++ and Python finite element library. I contribute the differentiable solver and the contact and homogenization components.
Teaching Assistant · New York University
Teaching Assistant · University of Science and Technology of China